“We need to get going into the future in terms of clean aviation” — Kim-Tobias Kohn
On this episode of the podcast I speak to Kim-Tobias Kohn who is a lecturer in Aerospace Engineering at the University of the West of England. Beside his main vocation, Kim is also an avid pilot and runs an electric skateboard startup company. Kim has garnered attention in the media and from aerospace societies in the UK for his unique university project of building an electric glider with his undergraduate students. For obvious reasons, building an electric passenger aircraft that can replace current fuel-powered airliners is significantly more challenging than replacing gasoline cars with electric vehicles. However, there is a growing grass-roots initiative developing in the UK that is attempting to solve some of the regulatory and technical challenges to realise this vision of electric aviation.
So in this episode Kim and I talk about:
the unique regulatory framework for experimental aircraft in the UK known as the E-conditions
the major technical hurdles that need to be overcome to make electric aviation a reality
how the UAV/drone sector is opening doors for larger-scale electric aviation
his university project of building an electric glider
his dreams for a student-led design, build and fly competition for electric aircraft
Over the last couple of months, a number of readers of the blog and listeners of the podcast have asked me about my research. Although there is a brief overview on the Research page, the information there probably leaves too many things unsaid to form a clear picture of what we trying to achieve. On the other hand, going into the nitty-gritty details of the mathematical models, computer methods and prototypes that we are developing will probably bore most readers of this blog senseless. In fact, communicating the technical details of research is often counterproductive when creating awareness with colleagues, the general public and funding bodies.
The power of stories
A much more effective way of communicating one’s ideas is through stories. For many centuries, stories were the predominant means of understanding life and society. Orators, poets and philosophers used analogies, metaphors and fables as arguments that voiced something important about reality. In this way, literature is not mere wordplay, but an effective means of communicating a complex topic in a manner that sticks, often with recourse to emotion. There is even evidence to suggest that stories have evolutionary utility, by being a means to relay important information such as a lucrative hunting spot. This hypothesis would suggest that a proclivity for stories is hardwired into our psyche. Some people, like Jonathan Gottschall, even argue that we live our entire lives by projecting a web of stories over everything we perceive through our senses.
In many ways, the great achievement of the Enlightenment, and Western thought in general, is a devotion to rationality: I don’t want to hear the story, give me the numbers instead. In his biography of Steve Jobs, Walter Isaacson argues that rational thought is not an innate human characteristic as such, but rather needs to be learned. Engineers—at least the good ones—should have plenty of this training. And perhaps this training is why we generally have a hard time communicating our ideas through stories—sticking rather to the technical details, which, generally speaking, tend to be a lot less inspiring.
Taking inspiration from nature: shape-adaptation
So what I will attempt to do in this post is to relay some of the technical details of our research through a vision of the future—a story of science-fiction if you will. It is a vision of shape-adaptive aircraft that can radically re-configure their shape as the operating conditions around them change.
Engineering systems are typically designed to meet multiple specifications stemming from (i) different functions that the system is meant to fulfill and (ii) the broad spectrum of environments it is operating in.
In terms of functionality, the most efficient approach is combining as many functions into one system as possible—so-called multi-functionality. For example, the wings of early aircraft such as the Wright Flyer, had two mechanisms for resisting aerodynamic loads and providing lift. The strut-and-wire-braced box truss provided bending rigidity and torsional stiffness against excessive wing bending and wing twisting, while the fabric wing skins provided the aerodynamic profile. The structural and aerodynamic functions were separated into two systems, and neither contributed to the other. In modern, stressed-skin designs, the externally visible wing skin serves both as an aerodynamic profile and also provides structural support.
When the operating conditions around an aircraft change, the situation is a bit more complicated. In isolation, different conditions can push the design in opposite directions, meaning that some form of design compromise is needed. The disadvantage of a compromise is that the aircraft will perform sub-optimally in most, if not all, of the individual operating conditions.
A solution to this conundrum is adaptation, also known as morphing, which would allow structures to change geometry and/or material properties in response to changing conditions. As with many good ideas we can take inspiration from nature. For example, birds can adapt the camber and angle of attack of their wings to react to different flight conditions. On modern aircraft wings, leading-edge slats and trailing-edge flaps, which are used to increase the lift-generating capabilities of wings at slow airspeeds, crucial for landing and takeoff, are manifestations of such adaptation. Even though these devices are effective and reliable, they rely on ancillary devices, such as heavy hydraulic or electric actuators, to facilitate the wing shape adaptation. By flexing and relaxing their wing muscles, birds have the ability to adapt between many different wing configurations, and due to the information-processing capability of the nervous system, this happens quickly and on the fly.
Hence, the challenge for engineers is how to embed shape-adaptive technologies in a multi-functional manner. And ideally, we would want both the actuation (think muscles), sensors (think nerves) and information processing (think brain) to be integral to the materials or structure. Only in this way will it be possible to design seamless and aerodynamically efficient aircraft that have the ability of sentient organisms to adapt to a wide array of changing environments.
An historic aside
The biomimetic inspiration for morphing and adaptive technologies has been around since the dawn of powered flight. This is no surprise given that many of the early aircraft pioneers took their inspiration from nature—dissecting bird wings and observing birds in flight to borrow ideas for steering and control. For example, the Wright Flyer used flexible wingtips that could be warped using pulleys and cables. Even though this technique became known as wing warping, it is essentially a basic form of wing morphing.
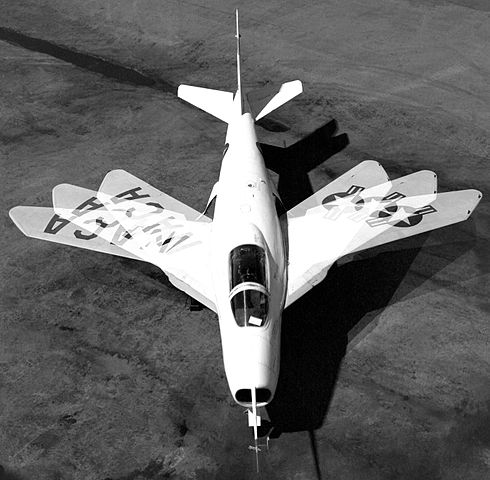
In the 1910-1920s many patents about variable camber wings, telescopic wings and variable angle-of-attack wings were filed, but none of these concepts made it into production. This can partly be explained by the shift from a more compliant timber and fabric construction to a stiffer metallic design. This allowed for greater flying speeds and bigger aircraft, but increased the energetic threshold required for shape adaptation. Interest in morphing aircraft intensified in the post-WWII era, when the technological race between the USA and the USSR provided the impetus for many novel ideas. One example, the Bell X-5, featured variable wing sweep in flight. Wing sweep reduces the effective airspeed across the lifting surface and can therefore be used to prevent supersonic shocks—a source of parasitic drag. The faster you want to fly, the greater the required sweep, and hence this adaptive feature allowed the X-5 to fly more efficiently at subsonic and supersonic speeds. The same concept was successfully implemented in the MiG-23, Grumman F-14 and Rockwell B-1B. Apart from moving slats, flaps and control surfaces present on most aircraft today, the most prominent modern example of morphing is probably the drooping nose of the Concorde, which was used to find a compromise for better cockpit visibility during landing and streamlining at cruise.
These early morphing ideas revolve predominantly around mechanically operated devices. That is, multiple components are joined by a mechanical hinge and the different components are then moved relative to each other by an actuator. Starting from the 1990s, new developments in materials science catalysed a shift from mechanical devices to novel materials. For example, during the late 1990s NASA Langley and DARPA led the Morphing Project and Smart Wing programme, which led to wing prototypes with gapless and hingeless leading- and trailing-edge control surfaces. NASA also released its now renowned artist impression of a morphing aircraft set in the year 2030, with wings that are capable of sweeping back and forth, changing shape and with compliant feather-like control surfaces for extreme manoeuvres.
Over the last 20 years, lots and lots of different materials have been used for a range of morphing technologies and concepts. Many of these technologies, ranging from flexible elastomers and honeycomb-type auxetic materials, to deployable structures and shape-memory metals, are summarised in the excellent review paper by Thill et al. from 2008. One particular concept, the FlexSys Mission Adaptive Compliant Wing (MACW), which has a moveable internal structure covered by a flexible skin and is capable of morphing the trailing edge through an angle of 20°, has been undergoing extended flight tests. One of these tests on the Scaled Composites SpaceShipOne suggests that the MACW could lead to 15% in fuel savings due to an improved laminar flow profile and minimal flow separation.
A shift in perspective: Well-behaved non-linearity
To most engineers, non-linearity is something to avoid. In a linear system, cause and effect are proportional—if I apply a force of 100 N to a beam and it bends by 1 mm, then I can expect it to bend by 2 mm for a force of 200 N and 4 mm for a force of 400 N. What is more, for a more complex situation with many interacting parts, a linear system is always a simple addition of its parts. This means a multi-part system can be broken apart, its constituents analysed individually, and the behaviour of the whole system deduced from an aggregation of the constituents. This linear decomposition is not possible for a non-linear system, which means that (i) non-linear systems are more complicated and costly to analyse, and (ii) the non-linearity can lead to unwanted and counter-intuitive effects.
One example of structural non-linearity is an instability. In aerospace engineering, minimising mass is the main design driver for more efficiency. No matter if you are trying to hold an aircraft aloft or shooting a rocket into space, the lighter your machine, the easier your task. This drive for lightweighting leads to thinner and thinner structures, where instabilities (like buckling) play a greater and greater role. In general, buckling is the tendency of thin-walled structures (struts and plates) loaded in compression to spontaneously bow out-of-plane (bend) at a critical value of compression. The buckling load varies with the cube of the strut’s or plate’s thickness, and while minimising thickness is very effective for reducing mass, it means that the susceptibility to buckling shoots up very quickly. Buckling is a non-linear event because the structure fundamentally changes its deformation mode—from one involving only compression, to one involving bending. Because there was no bending component pre-buckling, the bent post-buckling state cannot be a simple aggregation of pre-buckled states, and hence the phenomenon must be non-linear.
In traditional engineering design, buckling is considered as an unwanted “failure” mode to be treated no differently than material fracture, fatigue or plastic deformation. This traditional view is for good reason because buckling can cause a structure to lose its stiffness, and in the worst case, collapse. However, seen in a different light, the change in deformation mode brought on by buckling, can also be viewed as an opportunity for well-behaved shape-adaptation.
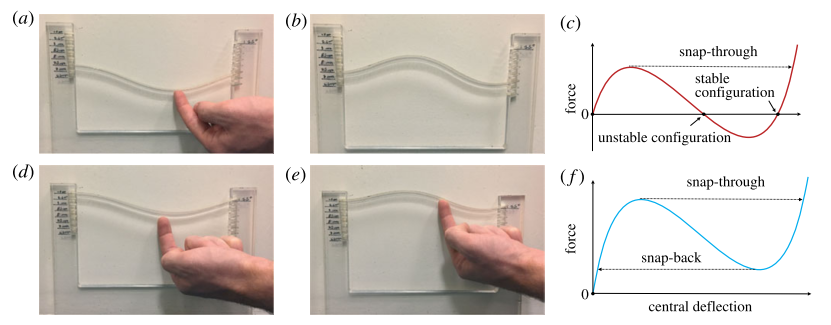
This concept can be illustrated using an example that will be familiar to most people who have sat through an introductory mechanics course as an undergrad—the Euler strut pictured above. Take a thin strut and pin the two ends so that they cannot move perpendicular to the strut axis. Then apply a compressive load by moving the two ends closer together. For an idealised strut with no geometric imperfections and with the load perfectly aligned with the strut axis, the strut will remain flat and simply compress. At a critical value of the applied load, the strut will suddenly bow out-of-plane, i.e. bend into one of two mirror-symmetric sinusoidal shapes. By applying a load perpendicular to the strut axis, the structure can now be snapped from one sinusoidal shape to another. This is indeed a pronounced snap, whereby the strut needs to be actively pushed in the direction of the other shape, but once a critical point is reached (a so-called tipping point), the strut suddenly and automatically transitions to the other shape without any further expenditure of energy. And once the load is removed, the structure will happily stay in this second configuration.
This is known as as bi-stable structure because there are two distinct configurations, which are both stable under no applied transverse load. These bi-stable systems are attractive for shape-adaptation, because to facilitate the shape change, energy only has to be expended to reach the snapping point, and thereafter the structure will happily settle into the second configuration.
Of course, this system is rather simple and these two sinusoidal shapes are not directly useful for the large spectrum of shape-adaptations we would want to achieve for real aircraft structures. However, even for this simple example, the design space is relatively large because the two strut ends can be moved or rotated relative to each other such that the initial shape of the strut is no longer flat but curved. In this manner, a wide array of different configuration pairs is attainable. Furthermore, by varying the degree of compression the post-buckled strut can be designed so that one of the two configurations is unstable if the snapping load is removed. This means that the structure can be snapped from an initially curved shape into another, and when the transverse load is removed, the strut will automatically snap back to its previous shape. This is generally known as a monostable snapping device.
Multistability and snap-through. (a) The application of a transverse load causes snap through into the inverted stable shape (b). (c) The applied load increases until it reaches a critical value. At this point, the beam snaps through a region of instability, where applied load decreases, reaching a second stable branch. Upon load removal, the structures settles in the secondary stable state. Similarly, a monostable buckled structure snaps from its first (d) to its second inverted configuration (e) when a transverse load is applied, but, as shown in (f), load removal causes snap back to the original unloaded equilibrium (d). Reproduced from Arena et al. (2017) Adaptive compliant structures for flow regulation. Proc.R.Soc.A 473: 20170334
Hence, from these general concepts illustrated via a small toy model, it follows that it is possible to take advantage of concepts such as bi-stability and snap-through instabilities to induced repeatable and well-behaved shape changes.
An example: a shape-adaptive air inlet
The multi-stable behaviour described above can, for example, be used to design an adaptive air inlet for engine cooling on car bonnets or jet engine covers. In this situation, you generally want the air inlet to be open at low velocities to maximise the air flow into the engine. At higher velocities, however, enough air is impinging onto the hot parts of the engine that these additional cooling ducts can be closed to reduce the induced drag.
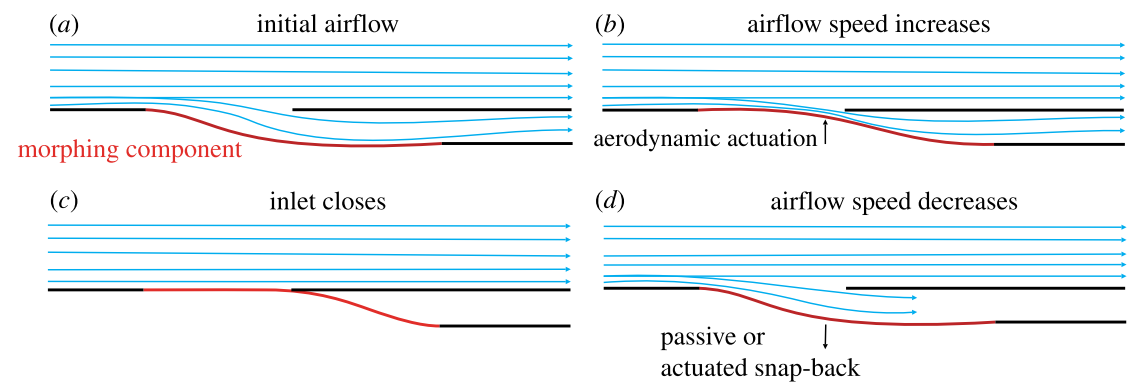
Consider, for example, the schematic air inlet in the figure below and assume that it is designed to be fully open at low air speeds. Considering the tradeoff between cooling performance and drag described above, at a critical air speed we would like the air inlet to automatically snap-shut for drag reduction. Furthermore, once the air-speed increases, the air inlet should open-up again to facilitate cooling. Ideally, this mechanism is to be designed autonomously without recourse to additional sensors or actuators. In fact, the fluid flow over the inlet creates a pressure field which can be used to actuate the adaptive air inlet, and the amount of compression of the inlet, i.e. the post-buckled state, plays the role of an integral sensing and control system.
An increase of fluid velocity into the inlet generates an area of low static pressure over the adaptive component. This pressure field is equivalent to a transverse load described above and causes the adaptive component to be sucked upwards. At a critical velocity, the low static pressure field exceeds the tipping point and the inlet snaps shut. If the device is designed to be bistable, then an additional actuation device is required to open the inlet up again. However, if the inlet is a monostable snapping device, then it will automatically open again once the airspeed is reduced and falls beneath a certain threshold. In this manner, a non-linear snapping air inlet can be used to automatically open and close a cooling duct purely by interacting with the fluid around it.
In our lab we have built and successfully tested such an adaptive air inlet in a wind tunnel. The two options of bistable and monostable snapping behaviour are clearly visible in the video below. Our current research is looking into the question of whether this behaviour can be extended from bistability to multi-stability. This would allow us to introduce an intermediate stage between the fully open and closed states for reduced air flow into the duct.
The question of control
The shape-adaptive air inlet is an example of a passive morphing device. Passive control refers to the ability of a system to react and adapt to external stimuli without having additional sensory, information processing or actuating devices. For example, no pressure sensors were attached to the air inlet to provide a signal to an external actuator to close the duct. Instead, the sensing, actuating and control functions were entirely embedded within the non-linear mechanics of the air inlet. The pressure field provided the actuation, the tipping point acted as an on/off switch, and the inherent stability of the second configuration acted as control. Such passive control systems are attractive from a minimal design perspective, and nature has found uses for passive control in the ruffling of birds’ feathers and adaptive shark scales for boundary layer control.
However, most shape-adaptive systems in nature are of the active type, where sensors (nerves) provide information to a central information processing unit (brain), which then provides an action signal to actuators (muscles). The beauty of biological organisms, may they be birds or even “smart” plants like the Venus flytrap, is that the entire control system of sensing, information processing and actuating is very efficiently contained within the organism. For example, the modern control systems of hydraulic lines and actuators that drive slats, flaps and control surfaces on an aircraft seem clumsy compared to the integral and lightweight solutions that evolution has crafted.
Of course, nature has undergone 4 billion years of evolution to arrive at these solutions, and so it is no wonder that our systems are comparatively ad hoc. But what seems crucial is that the three functions of sensing, information processing and actuation need to be scaled down, distributed more evenly and integrated tightly within the surrounding structure. Consider the musculoskeletal system of your arms, which can be understood as a tightly layered system. You have bones to provide structure, muscles layered on top for actuation, nerves running through muscles as lines of communication, and a further layer of skin to contain everything and provide sensory means to probe your surroundings (touch and heat).
Focusing on this concept of a layered structure, only in the last 1-2 decades have we gained the manufacturing expertise to produce such structures and materials with fidelity. Classic manufacturing techniques are subtractive in nature. Take a big billet of metal and cut everything away which is not your desired object. Contrast this to the modern additive manufacturing techniques of 3-D printing and laminated composite materials. Here, you create an object by layering material bit by bit, creating the whole unit from the bottom up. In the case of 3-D printing, a nozzle ejects material in pre-defined paths, whereas advanced composite laminates are manufactured by stacking layers of fibre-reinforced plastic on top of each other. Both these manufacturing techniques have the unique possibility of combining different material systems on the go, and even inserting additional components throughout the manufacturing process.
For example, consider an analogue to your arm renditioned as multiple material layers. Take a couple layers of carbon fibre composite to provide structure, layer on top of that a layer of magnetostrictive or piezo-electric material as a muscle and a layer of modern thin-film integrated circuitry. Hold everything together by a soft, impact resistant layer studded with sensors, and voilá, there goes your cyborg arm. Of course, this is a dramatic over-simplification of a potential solution, and to date, entirely science fiction. But the utility of this thought experiment is to plant a flag somewhere ambitious, which can then serve as a motivating goal. We might not arrive at this precise reality in the future, but the technology that will be developed just by embarking on this journey will certainly be novel and exciting.
Conclusion
So here you have it: a vision for the future of shape-adaptive aircraft featuring smart and multi-functional materials/structures. Advances in material science, manufacturing technology and compliant integrated circuitry now allow us to embed intelligence into engineering structures. This means structures will no longer just resist loads but have other integrated functions like sensing, information processing and actuation embedded within them. Furthermore, appreciable shape changes imply a degree of non-linearity and the shift from avoiding non-linearity to exploiting it for novel functionality opens up an entirely new frontier for innovation.
Acknowledgements
As with most modern research, there is a group of engineers working on these ideas, and I am just one member of this group at the Bristol Composites Institute. The people involved in this project are Alberto Pirrera, Paul Weaver, Gaetano Arena, Raf Theunissen and Alex Brinkmeyer. The work on the adaptive air inlet was funded by the Engineering and Physical Sciences Research Council (EPSRC).
“You could say: What could we possibly do next? You look back at history and say: All the shelves must be full now! We must have the capabilities to do everything we need. And yet, we still go on…It’s your generation that is going to Mars. So please, can you get on with it and do it, because I want to enjoy it from the augmented reality that other engineers are going to produce.” — Ian Lane
This episode features Ian Lane, Senior Expert in Composite Analysis for Airbus UK. Ian has more than 40 years of experience in the aerospace industry and his career has taken him from British Hovercraft to British Aerospace, Westland Helicopters and finally to his current role at Airbus. On top of this broad aerospace background, Ian’s specialty are modern composite airframes and he was the lead stress engineer on the Airbus A400M and Airbus A350. Ian is also a Visiting Professor in Aerospace Engineering at the University of Bristol, and a great example of an industry leader who knows how to inspire the next generation of young engineers. Indeed, Ian is actively involved with the Airbus Fly Your Ideas campaign, and a regular attendee at many international research conferences.
In this episode Ian and I discuss:
his career progression from apprentice to Senior Expert at Airbus
the incredible safety record of the aerospace industry
why the demise of Concorde wasn’t a step backwards
how Airbus fosters innovation and out-of-the-box thinking
why inclusion and diversity in engineering are so important
“There’s been a lot of good press from the science community on self-assembly of atoms. Well, I guess what I’m looking for is self-assembly and disassembly of large-scale structures…There is all sorts of exciting things we can do when [engineering] structures re-configure themselves.” — Prof. Paul Weaver
This episode features Prof. Paul Weaver, who holds a Bernal Chair in Composite Structures at the University of Limerick in Ireland, and is the Professor in Lightweight Structures at the University of Bristol in the United Kingdom. Lightweight design plays a crucial role in the aerospace industry, and Paul has worked on some fascinating concepts for more efficient aircraft structures. Paul’s research has influenced analysis procedures and product design at NASA, Airbus, GKN Aerospace, Augusta Westland Helicopters, Vestas (and many more), and in this episode we cover some of his past accomplishments and his vision for the future.
Central to this vision is artificial metamorphosis, which is a term that Paul coined to describe structures that re-configure by dis-assembly and re-assembly to adapt and optimise on the fly. Although Paul thinks that this vision of engineering structures is still 50 years into the future, he is well known for his work on a related technology: topological shape-morphing. The simplest example of a morphing structure is a leading edge slat, which is used on all commercial aircraft today to prevent stall at take off and landing. Paul, on the other hand, envisions morphing structures that are more integral, that is without joints and which do not rely on heavy actuators to function. Apart from artificial metamorphosis, Paul and I discuss
his teenage dreams of becoming a material scientist
his work with Mike Ashby at Cambridge University on material and shape factors
interesting coupling effects in composite materials that can be used for elastic tailoring
his work with Augusta Westland helicopters on novel rotor blades
why NASA contacted him about his research on buckling of rocket shells
“If you’re trying to put these structures into orbit, every gram counts. Not just every pound but every gram…So you are making structures that are operating at their margins.” — Dr Chauncey Wu, NASA Langley Research Center
Today’s conversation features Dr Chauncey Wu, who is a research engineer at NASA Langley Research Center in Hampton, Virginia. Chauncey has worked at NASA for more than 30 years, predominantly in the field of structural mechanics, and has been responsible for designing and testing a number of space structures that have been launched into space. Some examples of his work include structural analyses on the LITE telescope that was launched into space in 1994, as well as the optimisation of rocket propellant tank structures, and conceptual design studies of lunar lander vehicles and habitat structures for the colonisation of the Moon. In this wide-ranging conversation, we discuss:
Chauncey’s path to NASA as an undergraduate student
The history of NASA and the cultural shift compared to its predecessor, the NACA
The reason why rocket science is so hard
Chauncey’s recent research on a new type of lightweight composite material: tow-steered composites, which could be a game-changer for rocket booster designs
I am happy and excited to announce a new project on the Aerospace Engineering Blog. To go along with the usual blog posts, I will now be releasing regular podcast episodes that feature conversations with engineers and researchers in industry and academia to reveal their fascinating real-world stories of innovation, and provide a glimpse into the future of the industry by discussing cutting-edge research and promising new technologies. This episode is just a quick primer of what I have in mind, and the first “real” episode will be released in a couple of days.
The technological jump from no functional aeroplane to the first serious military fighter occurred in a mere 10 years. The Wright brothers conducted their first flight in late 1903 and by 1914 WWI broke out with an associated expansion in military flying. This expansion occurred almost entirely without the benefits of organised science in formal institutions and universities, and was led predominantly by tinkering aviators. Aircraft pioneers were often gifted flying-buffs or sporting daredevils, but very few of them had any real theoretical knowledge. This proved to be sufficient for the early developments, when flying was mostly a matter of strapping a powerful and lightweight engine to a basic flying design, and having the skills to keep the aircraft aloft and stable. Many pioneers, like Charles Rolls, paid with their lives for this mindset and it took many accidents from stalls and spins to figure out that something was amiss.
The specifications and operating environment of aeroplanes was, of course, entirely different from either cars or trains. Particularly the design requirements for reliable yet lightweight construction posed a conundrum for early aerospace engineers. To make something stronger, a rule of thumb is to add more material. For aircraft this means increasing the wall-thickness of the beams, frames and plates that comprise the aircraft. Of course, by making components thicker, the structure becomes heavier and less likely to fly. Furthermore, thicker structures are stiffer, which causes loads to be redirected within the structure, and rather counter-intuitively, can make the aircraft more likely to fail.
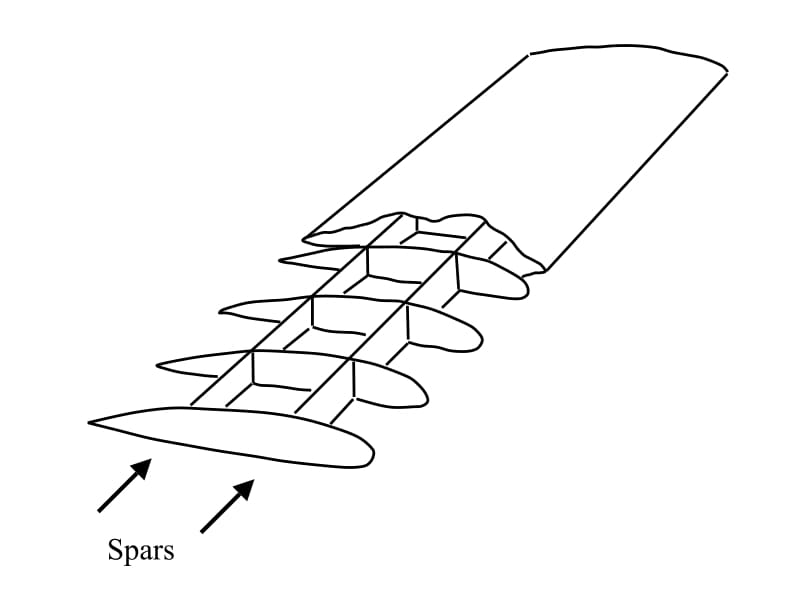
This counter-intuitive finding was played-out during the discovery of wing twisting. Wings are predominantly subject to bending forces due to aerodynamic lift that keeps the aircraft aloft. As this is entirely obvious, and since there was a great deal of acquired expertise in bridge building, wing bending loads were supported quite reliably by beams (spars) running along the length of the wing. The wing is, however, also subject to large twisting forces, and if these are not accounted for, the wing will twist-off the fuselage.
Spars running along the length of the wing and connected by a series of ribs
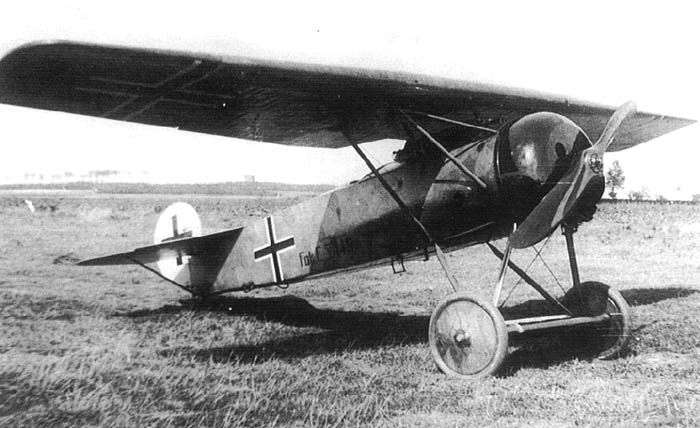
By 1917, the Allies had developed a certain degree of air superiority over the Western Front of WWI by means of better biplane construction. Out of necessity the Dutch engineer Anthony Fokker, working in Germany at the time, was developing a more advanced monoplane design with performance specifications better than anything the Allies had to offer. While biplanes are very light and were the preferred type of construction up to that point, their flying performance in terms of nimbleness and speed is limited due to the high drag induced by the aerodynamic interference of the two separate wings. There was thus a strong incentive to build faster monoplane aeroplanes. But since the fateful crash of Samuel Langley into the Potomac River in 1903, monoplanes had the reputation of being entirely unreliable.
Fokker D8
And indeed, as soon as Fokker’s new D8 aeroplane flew in combat situations, the wings started to snap-off as pilots pulled out of dives during dogfights. Being pressed for time, the D8 hadn’t gone through an extensive series of flying tests, and this cost many of Germany’s best pilots their lives. As a result, the German Air Force ordered a series of structural tests on the D8. As in the more standard biplanes of the time, the wings of the D8 were entirely covered by a thin fabric whose only purpose was to provide an aerodynamic profile for lift creation. The fabric itself did not carry any of the aerodynamic loads, and indeed all wing-bending loads were carried by two spars projecting from the fuselage and running along the length of the wing. The spars were connected by a series of ribs which served as attachment points for the stretched fabric. According to the testing standards of the time, the D8 aircraft was mounted upside down with weights suspended from the wings to simulate aerodynamic loads six times the weight of the aircraft. When tested this way, the wings showed absolutely no sign of weakness. When increasing the load beyond the factor of six, the wings began to fail in the aft spar such that the German authorities ordered all rear spars to be replaced by thicker and stronger ones. Unfortunately for the German military command, the accidents of the D8 become more frequent as a result of this intervention. Germany’s engineers now faced the perplexing conundrum that adding more material to the wings seemingly made them weaker!
At this point Fokker took matters into his own hands and repeated the tests in his own factory. What he found was that not only would the wings rise as a result of aerodynamic loads, but they would twist too, even though there was no obvious twisting loads being applied. Particularly important was the direction of twisting, which occurred as to twist the leading edge upwards, thereby increasing the angle of attack and the lift created by the wings, thus further increasing wing twisting, and so on in a detrimental feedback loop. As a pilot pulled up out of a dive, the extra lift needed to pull-off the manoeuvre was sufficient to initiate this catastrophic feedback loop, until the wings eventually twisted-off. Fokker had discovered the phenomenon now known as “divergence”.
But why did this divergent behaviour occur in the first place?
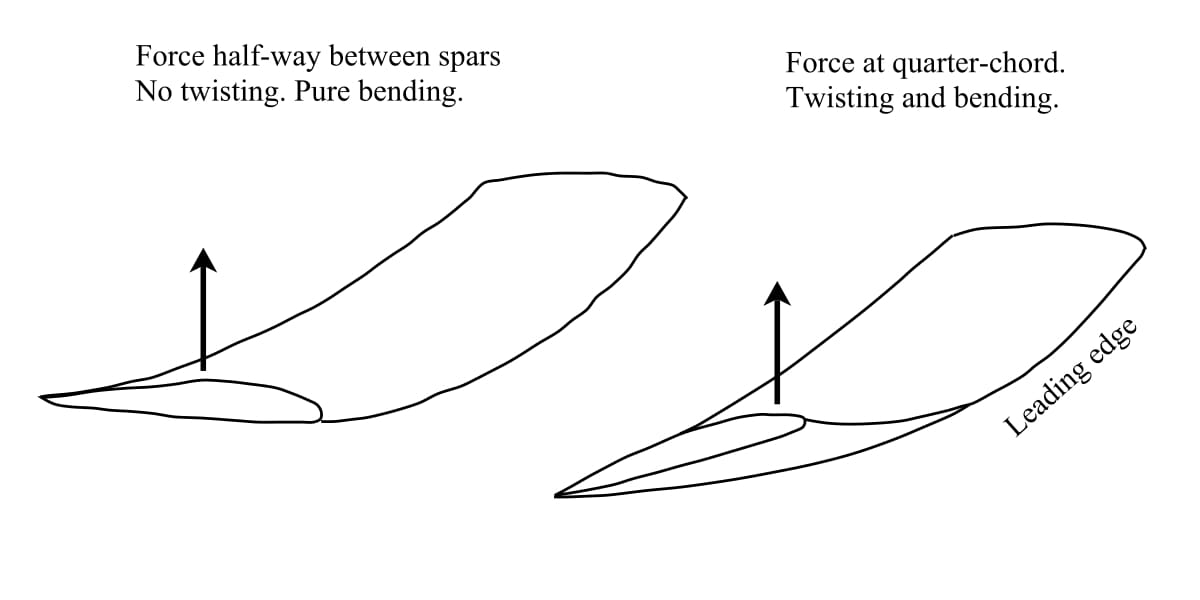
Imagine two horizontal and identical beams placed side by side and connected by a number ribs along their length to bridge the gap between them. One end of this assemblage is free and the other is rigidly supported (clamped). This simple construction is basically the fundamental structure of even the most modern aircraft. If a vertical load is applied exactly halfway between the two beams at the free end, then both beams will just bend upwards without any twist. However, if the vertical load is biased towards one of the beams then the assemblage will bend and twist at the same time, because the load carried by one beam is greater than the load carried by the other. The point where a load must be applied such that a structure bends without twisting is known as the flexural centre.
If a load is applied at the flexural centre (for a wing pretty much half-way between the two spars) the wing will only bend. But because the centre of pressure is located at the quarter-chord position, the wing bends and twists at the same time. The load is not applied at the flexural centre
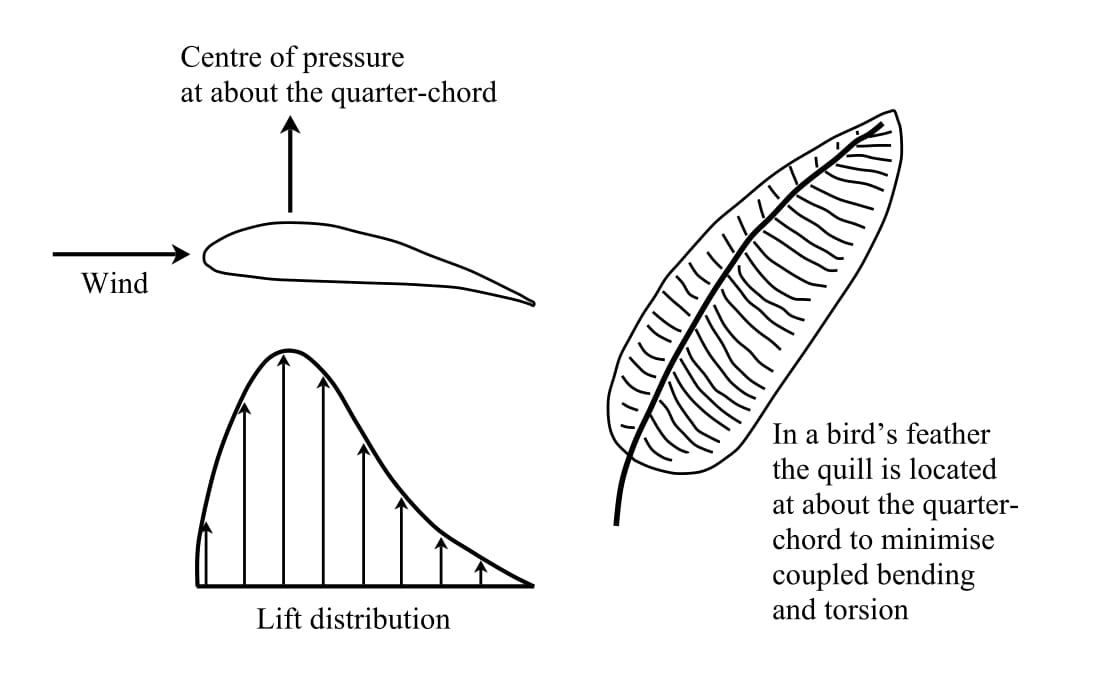
Of course, if there are more than two beams or if the beams are of different stiffness, then the flexural centre will not be halfway between the beams. In fact, the aerodynamic lift forces are distributed across the wing and do not really act at a single point. However, the distribution of aerodynamic pressure can be summed up and represented mathematically as acting as a point load somewhere between the front and rear spars. This point is known as the centre of pressure and may shift along the length of the wing. One might assume that the centre of pressure of a wing profile is situated nicely in the middle of the two spars, but this is not what happens. The centre of pressure for most wing profiles is in fact just behind the front spar, in the vicinity of the quarter-chord position, that is 25% of the chord length behind the leading edge. Therefore it follows quite simply that if the flexural centre and centre of pressure do not coincide, the wing must twist and bend at the same time. The extent of twisting naturally depends on this mismatch and the stiffness of construction in torsion. It is the designer’s role to minimise it as much as possible, and in fact, the thick quill of a bird’s feather is located at about the quarter span to minimise twisting.
Wing lift distribution with centre of pressure at the quarter-chord. A feather features a reinforcing “spar” at the quarter-chord to prevent twisting of the feathers
In the simple fabric-covered D8 monoplane, the flexural centre and torsional stiffness of the wing depended entirely on the two wing spars. In early designs of the D8, the centre of flexure was pretty much bang in the middle between the two spars, and the fruitless attempts of beefing-up the rear spar only moved the flexural centre further to the rear and away from the centre of pressure at the quarter chord. So Fokker decided to reduce the thickness of the rear spar, thereby not only solving the problem of divergence but also making the aircraft lighter and a serious menace to the British and French biplanes.
Fokker also came up with a second design evolution that enabled monoplanes. In the early fabric-covered monoplanes the torsional stiffness of the wing is provided entirely by differential bending of the two spars. Not much can be done to improve the torsional stiffness by tinkering with the design of these spars. This was part of the reason why monoplanes were forbidden in the early days of flying. It was a safety precaution, and not a particularly unpopular one, because in practice many biplanes were not much slower than monoplanes and considerably more reliable.
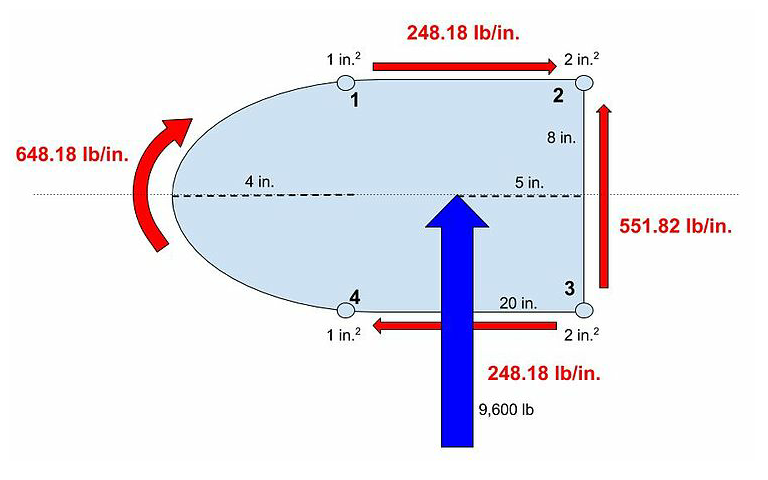
An example of the shear flow around a wing box due to a vertically applied load
As a structure is sheared it creates what is called shear flow – the shearing force divided by the length of material over which it acts. Because the fabric does not carry sufficient loading, the early fabric-covered monoplane construction is considered an “open” cross-section as shear cannot flow from one spar to the other. The strutted and braced construction of the biplane, however, has the advantage of creating a closed “torsion box”. The torsion box of biplanes creates a closed cross-section and the shearing forces can flow around the material to optimally resist torsion. Torsion is therefore ideally resisted by any box or tube whose sides are continuous. The second breakthrough of monoplane construction was therefore to replace the fabric with thicker sheet-metal that could carry load. Now the closed aerodynamic surface of the wing could provide the job of resisting shear loads efficiently, while the two spars predominantly served to resist bending loads. In effect, this is an efficient division of labour concept even though it requires a much thicker and heavier wing to resist torsion.
References
[1] J.E. Gordon. Structures: Or Why Things Don’t Fall Down. DeCapo Press. 2nd Edition, 2003.
A very important parameter when designing jet engines is specific power — the amount of power output divided by the mass of the engine. In general, a good heuristic to keep in mind when designing anything that moves is that maximising the power output per unit mass leads to a more efficient design. Afterburning is an exception to this rule. Yes, afterburning provides more thrust and therefore provides more bang for every gram of jet engine, but it is terribly fuel inefficient.
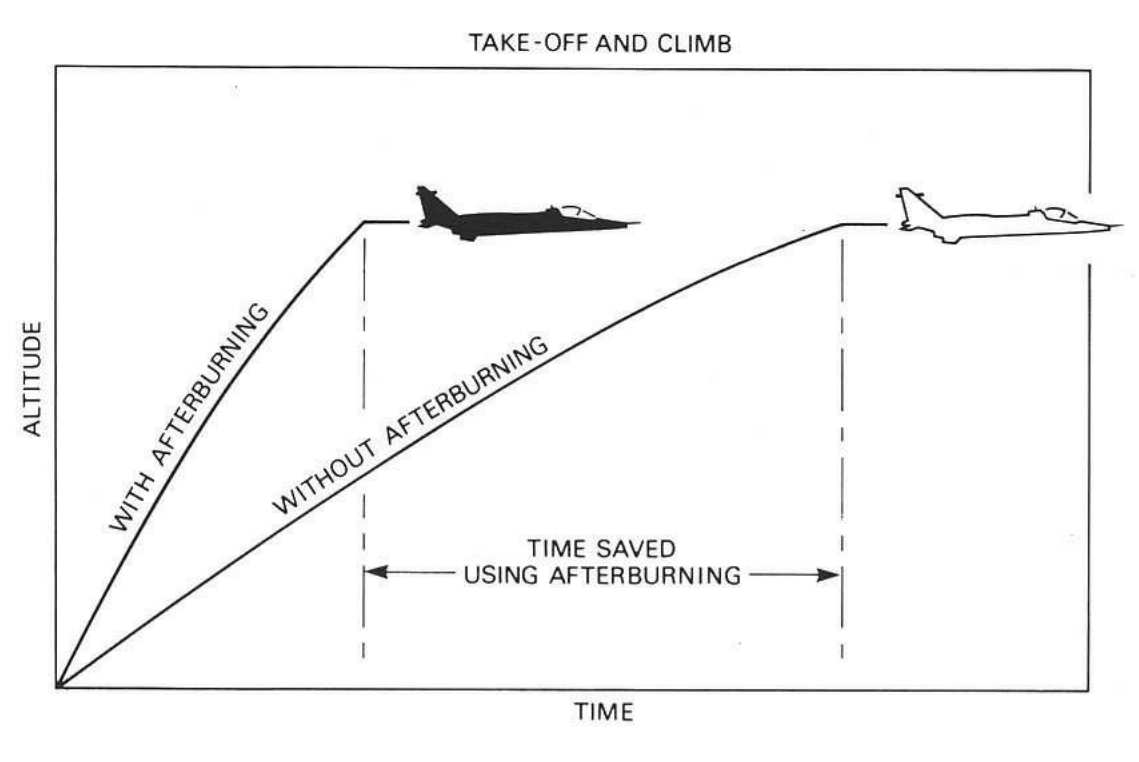
Afterburning, sometimes also called reheat, is a means of increasing the thrust of a jet engine in order to improve aircraft take-off and climb performance, to accelerate beyond the sound barrier, or in a military setting, for improved combat performance. Of course, we could simply increase the thrust by building a bigger and more powerful engine, but this naturally leads to a greater frontal area that impedes the oncoming flow, and therefore increases drag. Even though afterburning is incredibly fuel-inefficient, it is the best solution for enabling massive amounts of additional thrust at the switch of a button. This means an engine can be run in two modes – a fuel efficient, low thrust configuration and a fuel-inefficient, high-thrust configuration.
Effect of afterburning during take-off and climbing [1]
From conservation of momentum we know that the thrust of a jet engine is governed by the mass flow rate, , and the difference between the entry and exit velocities of air into, , and out of, , the jet engine.
For a fixed airspeed , this means that the level of thrust depends on both the exit jet velocity of the gases and the mass of air flowing through the engine per second. So to produce high levels of thrust we can either accelerate the exhaust gases to a greater velocity, or just increase the amount of air that is being sucked into the engine. Early turbojets attempted to maximise the exit jet velocity in order to create more and more thrust. The downside of this approach is that it decreases the efficiency of the engine. The propulsive or Froude efficiency of a jet engine is defined by the power output divided by the rate of change of kinetic energy of the air. The kinetic energy of the air represents the power input to the system. The power output is the product of force output, i.e. the thrust and the resulting air speed . Although this is an approximation, this equation summarises the essential terms that define aircraft propulsion. So, power output is
and the rate of change in kinetic energy is
such that the propulsive efficiency is
This means that for a fixed airspeed , the efficiency can be increased by reducing the jet exit velocity . However, decreasing the jet exit velocity decreases the thrust unless the mass flow rate is increased as well. Note that the advantage of increasing the mass flow rate is that it does not have an effect on the propulsive efficiency.
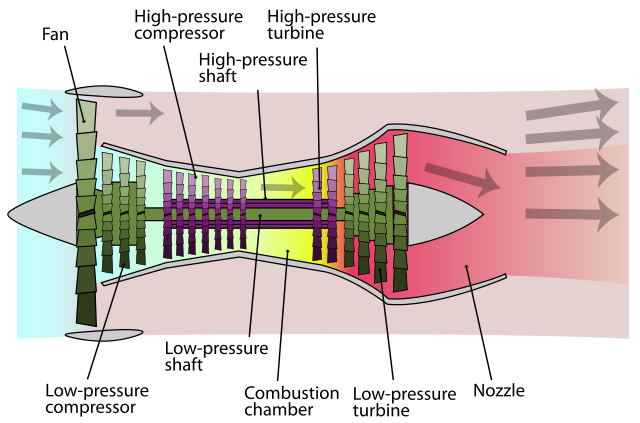
Schematic Diagram of Turbofan Engine
High bypass-ratio turbofan engines, which are the most common in modern airliners, are designed around this second principle – the big fan at the front sucks in tons of air, but because this flow bypasses the combustion chamber, it is not accelerated to a high exit velocity. The advantages of this design is that increasing the bypass ratio yields better fuel efficiency which means that turbofans can be operated over long periods (great for long-haul commercial passenger flights).
The downside, of course, is increased size and induced drag, which is a nightmare for nimble fighter aircraft. In fighter aircraft you want a small and compact engine that provides tons of thrust. Fuel efficiency is typically of secondary concern. Therefore, an afterburner naturally addresses the first principle we discussed above – accelerating the exhaust gases to higher velocity. This generally means that we can shrink the size of the engine and decrease the bypass ratio to provide better aerodynamic performance.
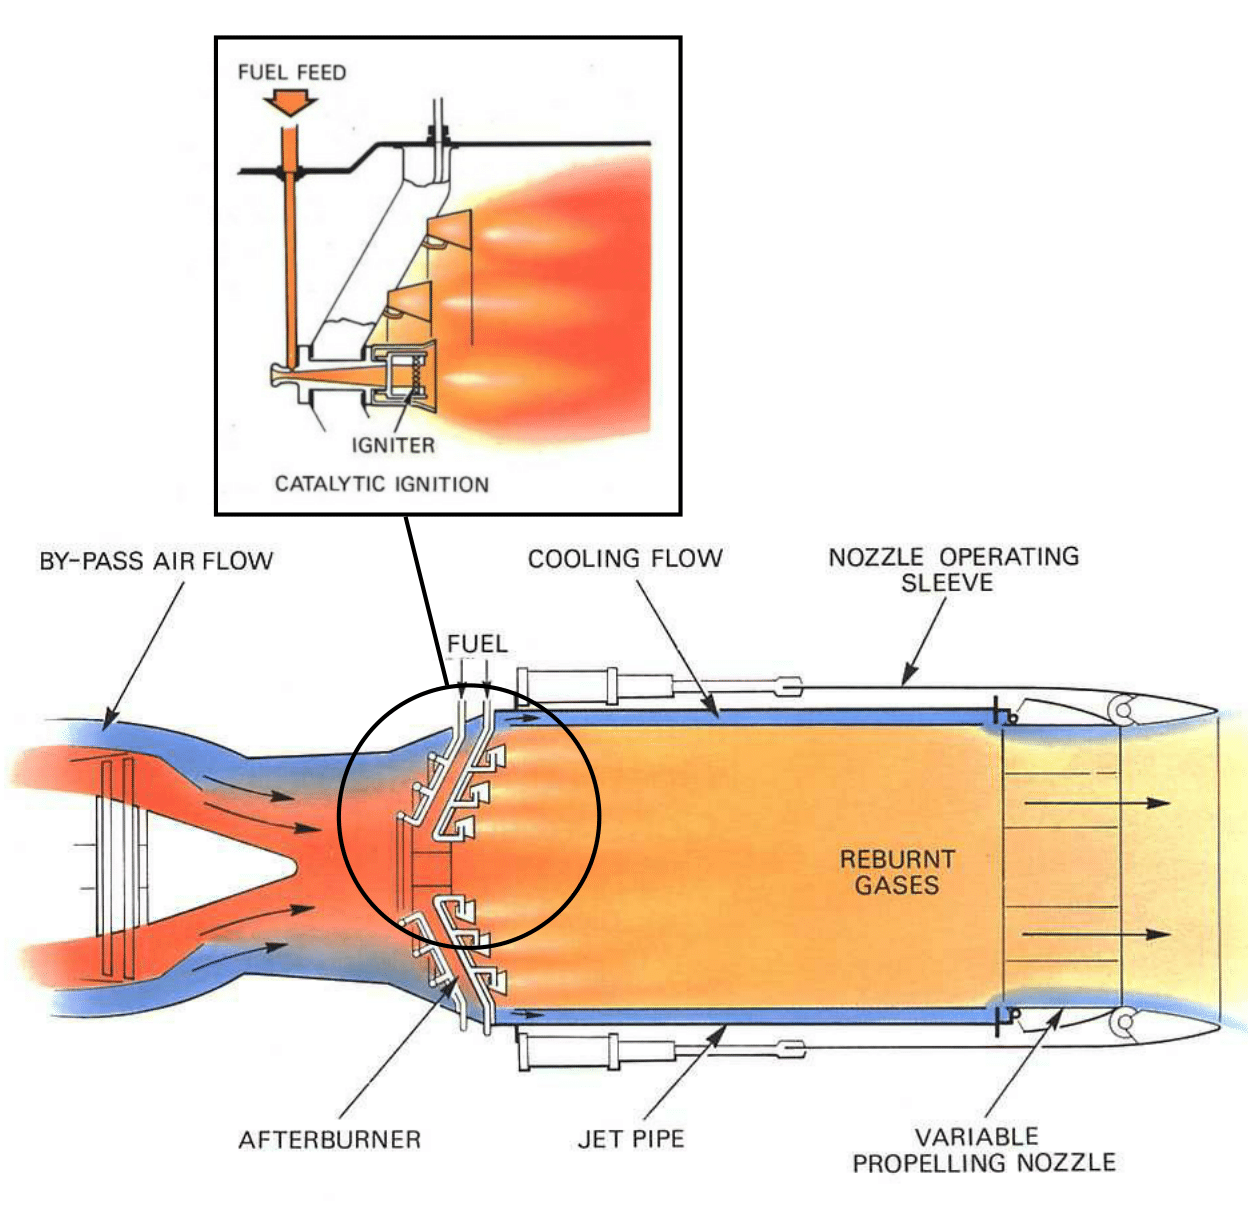
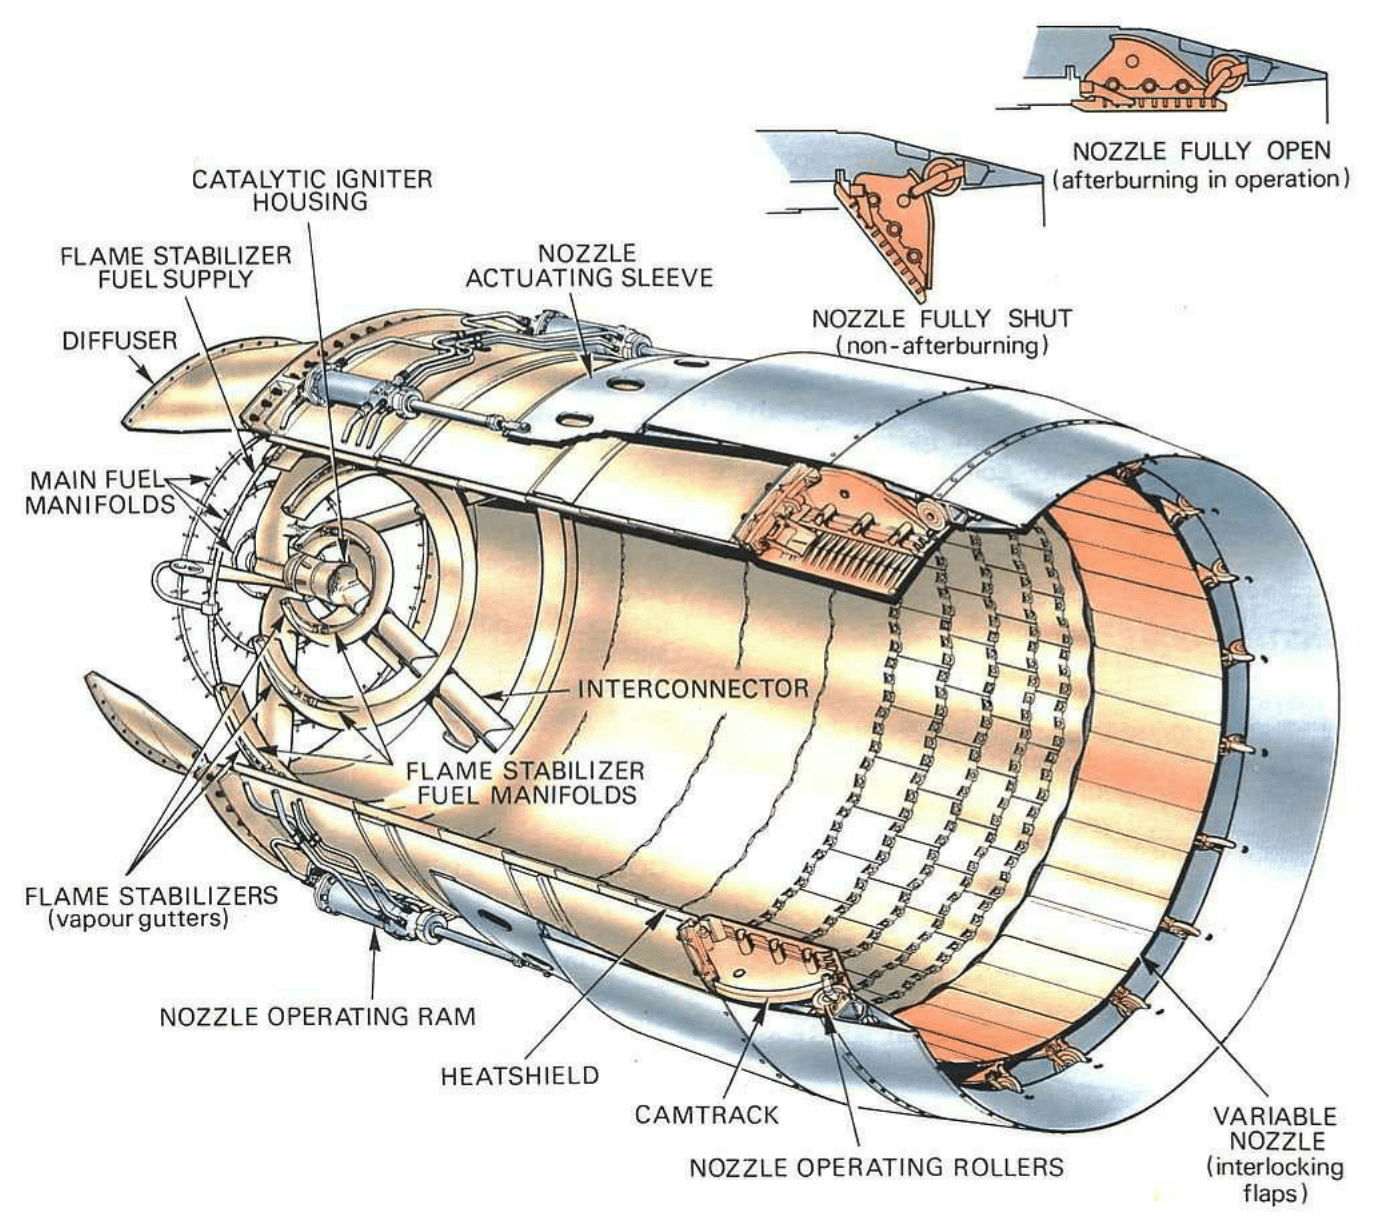
Schematic of afterburning components and functionality at the tail end of a jet engine [1]
As shown in the figure above, afterburning is achieved by injecting extra fuel into the hot exhaust gases that are being expelled by the turbine stage. The gas inside the jet engine is highest just before entering the turbine (just after combustion), and this turbine entry temperature is often the limiting design driver of the entire jet engine. Today, the turbine entry temperature is actually greater than the melting point of the metal used to make the turbine blades, but clever single-casting manufacturing methods and intricate cooling ducts inside the turbine blades guarantee that the blades do not creep excessively. To further limit the turbine entry temperature the combustion just prior to the turbine stage typically occurs at an oxygen-rich ratio such that sufficient oxygen is present in the hot gases flowing through and exiting the turbine. The hot jet exiting the turbine contains sufficient uncombusted oxygen that spraying more fuel into the jet pipe, and igniting the ensuing fuel-oxygen mix with a little spark raises the temperature to about 1700°C, and the related increase in the pressure forces the gases through the exhaust nozzle at increased velocity.
The hot jet from the turbine flows into the jet pipe at a velocity of around 250 m/s to 400 m/s, and this velocity is far too high to guarantee stable combustion in the jet pipe. Just prior to the jet pipe, the cross-sectional area of the exit portion to the turbine increases to diffuse the flow to lower velocities. However, because the standard injection rate of kerosene at a good fuel-to-oxygen mixture is only around 1-2 m/s, the kerosene would be rapidly blown away even by the diffused jet stream. To prevent this a vapour gutter is placed just prior to the fuel injection nozzles that spins the jet into turbulent eddie currents, thereby further slowing down the hot turbine exhaust gases and allowing for a better mixture of fuel and jet stream. A common misconception is that due to the high temperature of the gases exiting the turbine (around 700°C), the fuel-oxygen mixture in the jet pipe would combust spontaneously. Cooler combustion flames can develop at these temperatures, but because of the atmospheric pressure differences between ground level and altitude, a design that spontaneously combusts at ground level would never do so at altitude. To guarantee a stable and smooth reaction over a wide range of mixture ratios and flying altitudes, a high-intensity spark is needed.
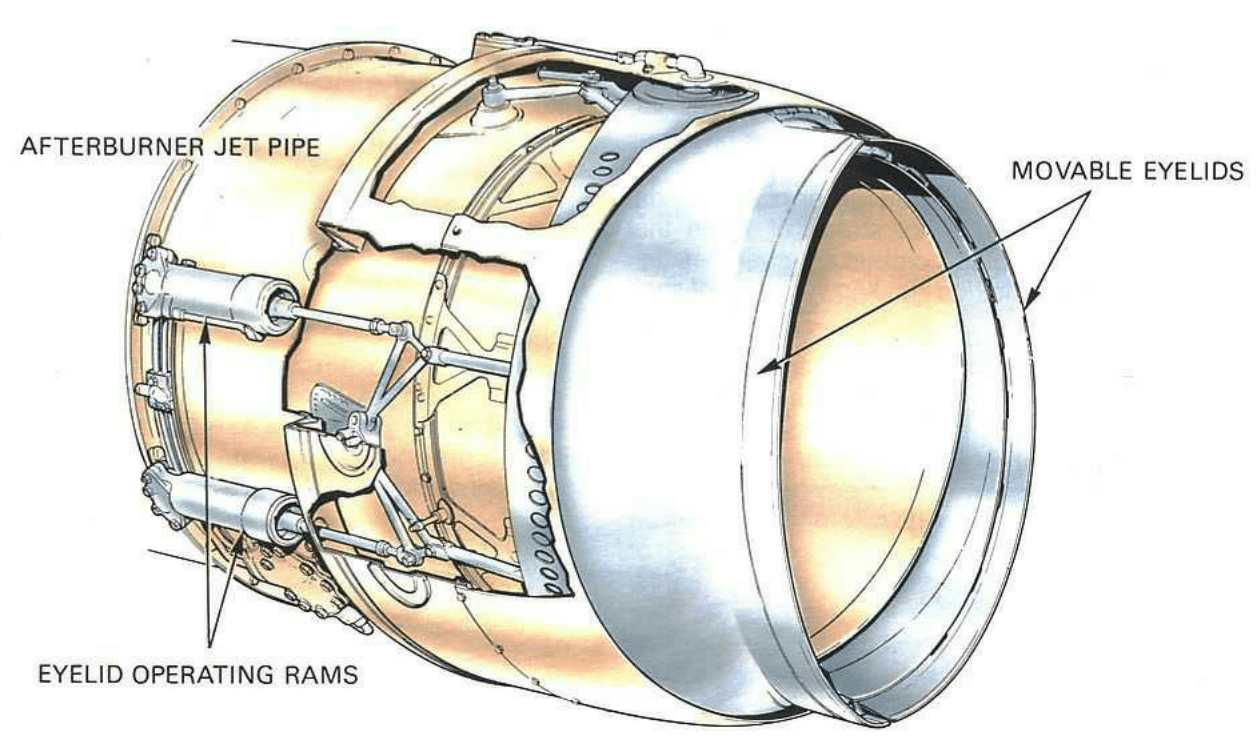
Two-position nozzle [1]Variable-area nozzle [1]
To allow the jet to operate without afterburning, the jet pipe is fitted with a two-position or a variable-area propelling nozzle as shown above. When afterburning is not being used, the nozzle remains in its closed configuration, but opens when afterburning is initiated to increase the exit area and prevent pressure from building up in the jet pipe that can adversely affect the operation of the turbine. A two-position nozzle has two “eyelids” that can be moved irrespective of the other in order to open or close the nozzle area. A variable-area nozzle consists of multiple flaps situated side-by-side in a ring arrangement around the exit nozzle and hinged to the outer casing. The nozzles can rotate into or out of the flow by rotating rollers that are actuated by a camtrack and a linear actuator (operating ram). When afterburning is initiated, a fuel control unit determines the correct amount of fuel to flow into the jet pipe to provide the correct balance between increased jet pipe pressure and the pressure ratio across the turbine. The pressure ratio across the turbine is crucial for efficient operation of the jet engine as it provides the energy to operate the compressor stages. Therefore, the control system can automatically vary the nozzle exit area in order to maintain the correct pressure ratio across the turbine – the higher the degree of afterburning, the greater the build-up of pressure in the jet pipe, and thus, the greater the required nozzle area to reduce the load on the turbine.
Thrust and fuel consumption
The increase in thrust is a function of the increase in jet pipe temperature as a result of afterburning. For a perfectly efficient system, the relationship between the temperature ratio before and after fuel is burnt, and the thrust increase is nearly linear in the typical operating range with temperature ratios of 1.4 to 2.2. Within this range we can expect a 40% increase in thrust for a doubling of the temperature in the jet pipe. Thus, if afterburning raises the jet pipe temperature from 700°C (973 K) to 1500°C (1773 K) this results in a thrust increase of around 36%.
In a static test bed, thrust increases of up to 70% can be obtained at the top end, and at high forward speeds, several times this can be achieved. The lower the temperature exiting the turbine and the greater the extent of uncombusted oxygen, the greater the temperature increase in the jet pipe due to afterburning.
As is to be expected, afterburning naturally incurs a fuel consumption penalty, and this is why afterburning is typically constrained to short bursts. The aim of the compressor in a classic jet engine is to raise the pressure of the incoming air to the optimal pressure for efficient combustion. After expansion by the turbine stage, the gases are at a lower degree of compression, and therefore the fuel is not burnt as efficiently as in the combustion chamber between compressor and turbine. For a 70% increase in thrust the fuel consumption can easily double, but of course this increased fuel consumption is balanced by an improved performance in terms of take-off and climb. This means that the increased fuel consumption is balanced by the time saved to cover a desired distance or operating manoeuvre.
The inspiration of this post and the diagrams have all been taken or inspired by [1] Rolls-Royce (1996). The Jet Engine. Rolls Royce Technical Publications; 5th ed. edition (Amazon link). For anyone interested in jet engine design this is a beautiful book, describing lots of intricate details about jet engine design and presenting the information in an intuitive and visually pleasing manner using diagrams as used throughout this post. I can not recommend this book enough.
Aeroelasticity is the study of the interactions between dynamic, inertial and aerodynamic forces that arise when a body is immersed in airflow. The unique challenge of aeroelasticity is to analyse how vibrations, static deflections and lift and drag forces combine, and to make sure that any interaction of these three forces does not lead to inferior aircraft performance or even failure.
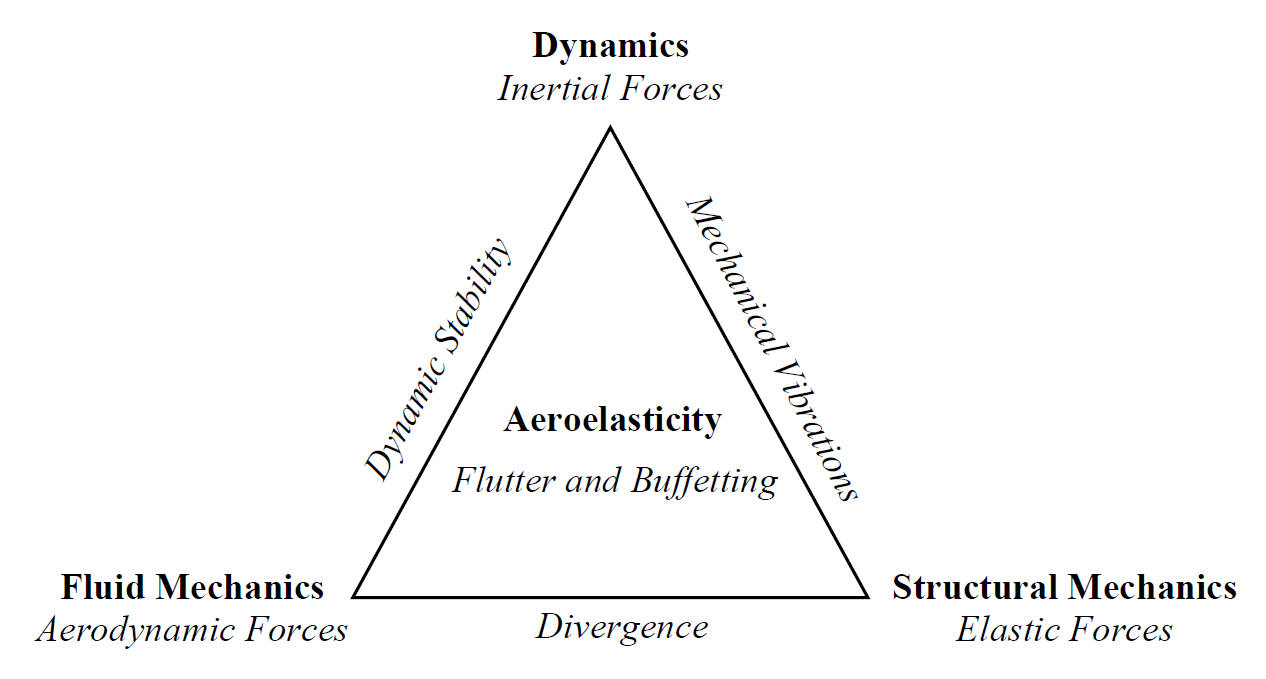
The triangle in the figure below is known as Collar’s triangle and each vertex shows one of the forces mentioned above. When all three forces interact simultaneously we are in the realm of aeroelasticity and common failure modes include wing flutter and buffeting. When inertial and elastic forces combine in the absence of aerodynamic forces we are in the classical domain of structural dynamics and essentially dealing with any sort of mechanical vibration that you would experience on any piece of moving machinery. The interaction of inertial forces and aerodynamic forces gives rise to aerodynamic stability problems. How does an aircraft react to small disturbances – do the oscillations dampen out or do they get worse over time? Finally, the interaction of aerodynamic forces and elastic forces can give rise to a phenomenon known as divergence, which is an effect where twisting of the wing becomes theoretically infinite and can cause wings to twist off.
The Collar Triangle defining aeroelasticity as “the study of the mutual interaction that takes place within the triangle of the inertial, elastic, and aerodynamic forces acting on structural members exposed to an airstream, and the influence of this study on design.”
The two most dramatic aeroelastic effects are flutter and divergence. Flutter is a dynamic instability, often of the wing, caused by positive feedback between the wing’s deflection and the aerodynamic lift and drag forces. The flutter speed is the airspeed at which the wing, or any other part of the structure, starts to undergo simple harmonic motion – much like the simple to and fro motion of a simple pendulum – and this vibration occurs with zero net damping. Zero net damping means that there is no dissipation of energy (think of a pendulum swinging for eternity) and so any further decrease in net damping will result in self-oscillation – the structure is basically forcing itself to vibrate more and more, which at some point, will naturally lead to failure.
As we all know, the lift force acting on a wing will tend to bend it upwards, but what is less well-known is that this lift force can also cause the wing to twist. This is because the centre of pressure, the point where the total sum of the lift pressure field is assumed to act on an airfoil, is not necessarily coincident with the shear centre, the point through which a bending load needs to be applied to get pure bending without any twisting. Imagine holding a ruler in one hand and pushing up on it with your other hand. If you apply the load along the central axis of the ruler, the ruler will only bend, but if you apply the load at one of the two sides you can see the ruler bend and twist ever so slightly. Most of the time, the shear centre of an airfoil is not coincident with the centre of pressure, and so a lift force produces both bending and twisting. A critical phenomenon called divergence can occur when this twisting of a wing increases the angle of attack, which consequently increases the lift force further or creates further mismatch between shear centre and centre of pressure, so that a feedback loop ensues until the wing diverges or essentially shears off. In fact, one of the Wright Brothers’ main rivals in the race to being the first at heavier-than-air flight was Samuel Langley, whose prototype plane crashed into the Potomac river in Washington D.C., and this is now believed to have occurred as a results of torsional divergence. Furthermore, torsional divergence was a large problem with many WWI fighter planes and required a lot of additional stiffening of the wings.
Forward-swept wings
One of the domains where divergence is particularly pernicious is in forward-swept wings. Simply put, wing sweep delays the onset of shock waves over the wings and therefore reduces the associated rise in aerodynamic drag caused by boundary layer separation. In slightly more detail, as air flows over a curved object, such as an aircraft wing, it accelerates due to centripetal forces and this means that an aircraft travelling slightly slower than Mach 1.0 (the speed of sound) can develop pockets of supersonic flow over areas with high local curvature, typically the wings or the canopy. For thermodynamic reasons,supersonic flows terminate in a shock wave which results in a sudden increase in the density of the air. This effect disturbs the smooth flow over the wing and creates vortices behind the aircraft, which means it is a form of parasitic drag. Sweeping the wing reduces the curvature of the body as seen from the airflow by the cosine of the angle of sweep. For example, a 45 degree sweep reduces the effective curvature by around 70% () compared to the straight-wing case. As a result, this increases the airspeed at which supersonic pockets start to form by about 30%, such that the aircraft can reach speeds much closer to Mach 1 before shocks occur.
Another way to think about the effect of sweep is to imagine the airflow over the wing as shown in the figure below. The effect of sweeping is such as to break the airflow into a component normal to the wing chord (“normal component”), and one along the span of the wing (“spanwise component”). The maximum curvature of the wing occurs along the wing chord, and the normal velocity component for the swept wing () is always less than the normal component for a straight wing ().
The figure above highlights another critical aspect of swept wings: the spanwise component. On a backward-swept wing the spanwise flow is outwards and towards the tip, while on a forward-swept wing it is inwards towards the root (see the figure below). Firstly, with the air flowing inwards towards the fuselage, wingtip vortices and the accompanying drag are reduced. Wingtip vortices form when the higher pressure air underneath the wing is sucked up onto the lower pressure top surface of the wing, thereby reducing the effective lift-generating surface of the wing. On most modern backward-swept airliners, winglets and sharklets prevent this phenomenon from occurring. Forward-swept wings similarly minimise this effect by re-routing some of the flow towards the wing root, and therefore allow for a smaller wing at the same lift performance. The second advantage of forward-swept wings is that shockwaves tend to develop first at the root of the wing, rather than towards the tips, and this helps to reduce tip stall. Aerodynamic control surfaces such as ailerons are typically located near the tips of the wings, because the further outboard, the greater their effect on controlling the rolling action of the plane. Tip stall essentially renders these ailerons useless, and therefore jeopardises the pilot’s control over the aircraft. As a result, the dangerous tip stall condition of a backward-swept design becomes a safer and more controllable root stall on a forward-swept design, providing better manoeuvrability at high angles of attack.
For all their merits, forward-swept wings suffer from one detrimental flaw – divergence. In a forward-swept wing configuration, the aerodynamic lift causes a twisting force that rotates the leading edge upward, causing a higher angle of attack, which in turn increases lift, and twists the wing further. With conventional metallic construction, additional torsional stiffening is typically required which adds weight, and is therefore sub-optimal in terms of aircraft performance.
Enter the Grumman X-29
The Grumman X-29 was an experimental aircraft developed by Grumman in the 1980’s, and flown by NASA and the US Air Force. The X-29 tested a forward-swept wing, canard control surfaces, and computerised fly-by-wire control to counter balance the various aerodynamic instabilities created by its airframe. From my perspective, the most important innovation, however, was the novel use of composite materials to control the aeroelastic divergence of forward-swept wings. At the time, composite materials were popular in the high-performance aircraft community as a means of creating stiff and strong structures at very low weight. In fact, composites were mainly used to save weight. However, the X-29 showcased a second advantage of this new material over classic metallic structures – multi-functionality.
Metals are isotropic materials, meaning that their stiffness is the same in all directions. The relationship between stress and strain along one direction of an aluminium panel is the same as in any other direction. Because composite materials are a union of stiff fibres held together by a resin matrix, we can manufacture panels that are stiffer in one direction than in another. This is because the composite material will be very stiff along the fibre direction but relatively compliant perpendicular to the fibre direction. In most fibre-reinforced composite materials, such as fibreglass and carbon fibre, this variation in stiffness is restricted to the plane of a single sheet of material known as an orthotropic lamina.
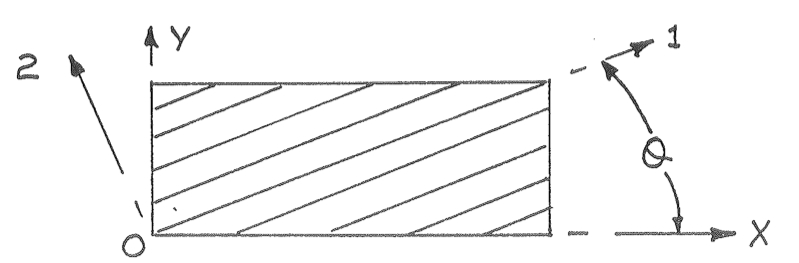
Consider one such layer of a continuous fibre-reinforced composite in the figure above. The material axes 1-2 denote the stiffer fibre in the 1-direction and the weaker resin in the 2-direction. If we align the fibres with the global x-axis and apply a load in the x-direction, the layer will stretch along the fibres and compress in the resin direction (or vice versa). However, if the fibres are aligned at an angle to the x-direction (of say 45°), and a load is applied in the x-direction, then the layer will not only stretch in the x-direction and compress in the y-direction but also shear. This is because the layer will stretch less in the fibre direction than in the resin direction. This effect can be precluded if the number of +45° layers is balanced by an equal amount of -45° layers stacked on top of each other to form a laminate, e.g. a [45,-45,-45,45] laminate. However, this [45,-45,-45,45] laminate will exhibit bend-twist coupling because the 45° layers are placed further away from the mid plane than the the -45° layers. The bending stiffness of a layer is a factor of the layer-thickness cubed plus the distance from the axis of bending (here the mid-plane) squared. Thus, even if the +45° and -45° layers have the same thickness, the outer 45° layers contribute more to the bending stiffness of the [45,-45,-45,45] laminate than the -45° layers do. Therefore, stretching-shearing coupling is eliminated in a [45,-45,-45,45] laminate as the number of +45° and -45° layers is the same, but bend-twist coupling will occur because the +45° layers are further from the mid-plane than the -45° layers.
Let’s now apply this effect at a wing level, i.e. a layup is used for the top wing surface and a layup for the bottom wing surface. At the global wing level, the layup is balanced because we have an equal number of and layers, but the layers are further away from the wing mid-plane than the layers. This means that the bending stiffness is dominated by the layers, and the wing will twist when it bends.
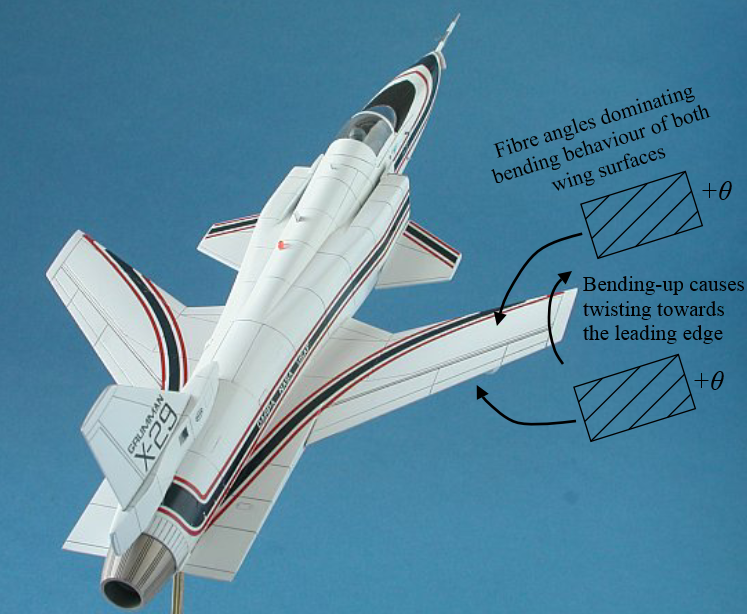
In the Grumman X-29, this bend-twist coupling was successfully exploited to prevent divergence in the forward-swept wings. As aerodynamic lift forces the wing tips to bend upward, the forward-swept wing wants to twist to higher angles of attack, but the inherent bend-twist coupling of the composite laminates forces the wing to twist in the opposite direction and thereby counters an increase in the angle of attack – divergence is avoided!
Bend-twist coupling in Grumman X-29 wings. Both top and bottom wing skin may have the same number of +theta and -theta fibre angles, but if the +theta angles are further from the wing mid-plane then they will dominate the bending behaviour and cause the leading edge to twist down as the wing bends up.
The Grumman X-29 is an excellent example of an efficient, autonomous and passively activated control system. Rather than adding more material to the wing to make it stiffer (but also heavier) an alternative solution is to use the bend-twist coupling capability of composite laminates. This capability is an example of elastic tailoring, and remains one of the most under-exploited advantages of composite materials. As the big aircraft manufacturers overcome the initial hurdles of using composites on a large scale with the 787 Dreamliner and A350-XWB, expect more and more of these multi-functional capabilities of composites to find their way onto aircraft components.
J.E. Gordon, a leading engineer at the Royal Aircraft Establishment at Farnborough and holder of the British Silver Medal of the Royal Aeronautical Society, wrote two brilliant books on engineering: “The New Science of Strong Materials” and “Structures – Or Why Things Don’t Fall Down”. Elon Musk has recommended the latter of the two books, and I can only encourage you to read both. In my eyes, the role of a good non-fiction writer is to explain the intricacies of a non-trivial topic that we can see all around us but nevertheless rarely fully appreciate. Something interesting hidden in plain sight, if you will.
With this in mind, let’s discuss an underappreciated topic from the world of materials science.
First of all, what do we mean by a material’s stiffness and strength?
To be able to compare the load and deformation acting on components of different sizes, engineers prefer to use the quantities of stress and strain over load and deformation. Imagine a solid rod of a certain diameter and length which is being pulled apart in tension. Naturally, two rods of the same material but of different diameters and lengths will deform by different amounts. However, if both rods are stressed by the same amount, then they will experience the same amount of strain. In our simple one-dimensional rod example, the stress is given by
where is the tensile force and is the cross-sectional area for a diameter , i.e. force normalised by cross-sectional area.
The engineering strain is given by
where is the change in length (deformation) of the rod and is its original length, i.e. the deformation normalised by original length.
For an elastic material deforming linearly (i.e. no plastic deformation), the ratio of stress to strain is constant, and for our simple one-dimensional example the constant of proportionality is equal to the stiffness of the material.
(Hooke’s Law).
This stiffness is known as the Young’s modulus of the material.
These two definitions of stress and strain illustrate a simple point. By dividing force by cross-sectional area and change in length (deformation) by original length, the role of geometry is eliminated entirely. This means we can deal purely in terms of material properties, i.e. Young’s modulus (stiffness), stress to failure (strength), etc., and can therefore compare the degree of loading (stress) and deformation (strain) in components of different sizes, shapes, dimensions, etc.
We can all appreciate that metals are incredibly strong and stiff. But why are some materials stronger and stiffer than others? Why don’t all materials have the same strength and stiffness? Aren’t all materials just an assemblage of molecules and atoms whose molecular bonds stretch and eventually separate upon fracture? If this is so, why don’t all materials break at the same value of stress and strain?
The stiffness and strength of a material does indeed depend on the relative stiffness and strength of the underlying chemical bonds, and these do vary from material to material. But this difference is not sufficient to explain the large variations in strength that we observe for materials such as steel and glass — that is, why does glass break so easily and steel does not?
In the 1920s, a British engineer called A.A. Griffith explained for the first time why different materials have such vastly different strengths. To calculate the theoretical maximum strength of a material, we need to use the concept of strain energy. When we stretch a rod by 1 mm using a force of 1,000 N, the 1 J of energy we exerted (0.001 m times 1,000 N) is stored within the material as strain energy because individual atomic bonds are essentially stretched like mechanical springs. Written in terms of stresses and strains, the strain energy stored within a unit volume of material is simply half the product of stress and strain:
Griffith’s brilliant insight was to equate the strain energy stored in the material just before fracture to the surface energy of the two new surfaces created upon fracture.
Surface energy??
It is probably not immediately obvious why a surface would possess energy. But from watching insects walk over water we can observe that liquids must possess some form of surface tension that stops the insect from breaking through the surface. When the surface of a liquid is extended, say by inflating a soap bubble, work is done against this surface tension and energy is stored within the surface. Similarly, when an insect is perched on the surface of a pond, its legs form small dimples on the surface of the water and this deformation causes an increase in the surface energy. In fact, we can calculate how far the insect sinks into the surface by equating the increase in surface energy to the decrease in gravitational potential energy as the insect sinks. Furthermore, liquids tend to minimise their surface energy under the geometrical and thermodynamic constraints placed upon them, and this is precisely why raindrops are spherical and not cubic.
When a liquid freezes into a solid, the underlying molecular structure changes, but the overall surface energy remains largely the same. Because the molecular bonds in solids are so much stronger than those in liquids, we can’t actually see the effect of surface tension in solids (an insect landing on a block of ice will not visibly dimple the external surface). Nevertheless, the physical concept of surface energy is still valid for solids.
So, back to our fracture problem. What we want to calculate is the stress which will separate two adjacent rows of molecules within a material. If the rows of molecules are initially metres apart then a stress causing a strain will lead to the following strain energy per square metre
From Hooke’s law we know that
and therefore replacing in the first equation we have
Now, if the surface energy per square metre of the solid is equal to , then the separation of the two rows of molecules will lead to an increase in surface energy of (two new surfaces are created). By assuming that all of the strain energy is converted to surface energy:
There is typically a considerable amount of plastic deformation in the material before the atomic bonds rupture. This means that the Young’s modulus decreases once the plastic regime is reached and the strain energy is roughly half of the ideal elastic case. Hence, we can simply drop the 2 in front of the square root above to get a simple, yet approximate, expression for the strength of a material
As the values of and vary from material to material, the theoretical strengths will be different as well. The surface tension of a material is roughly proportional to the Young’s modulus because the same chemical bonds give rise to both these properties. In fact, the relationship between surface energy and Young’s modulus can be approximated as
such that the strength of a material is approximately proportional to the Young’s modulus by the following relation
Given, the relationship between stress and strain we can conclude that the theoretical failure strain of most materials ought to be, approximately,
or 20% for basically all materials.
In everyday practise, most materials have failure strengths far beneath the theoretical maximum and also vary widely in their failure strains. To explain why, Griffith conducted some simple experiments on glass. After calculating the Young’s modulus from a simple tensile test and assuming a molecular spacing of Angstroms, Griffith arrived at a theoretical strength for glass of 14,000 MPa. Griffith then tested a number of 1 mm diameter glass rods in tension and found the strength to be on average around 170 MPa, i.e. 1/100 th of the theoretical value.
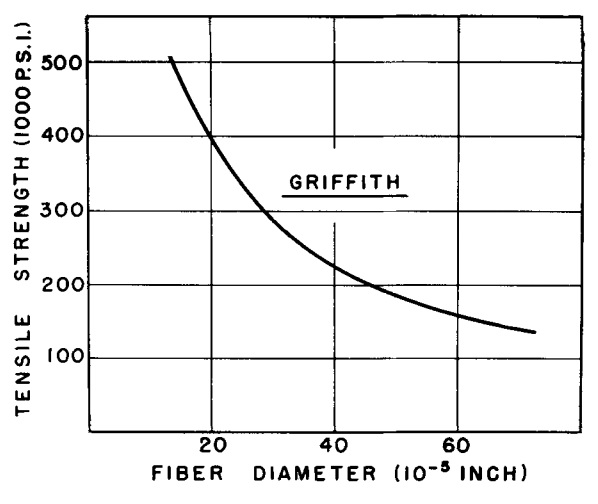
The pultrusion process used to create the glass rods allowed Griffith to pull thinner and thinner rods, and as the diameter decreased, the failure stress of the rods started to increase – slowly at first, but then very rapidly. Glass fibres of 2.5 in diameter showed strengths of 6,000 MPa when newly drawn, but dropped to about half that after a few hours. Griffith was not able to manufacture smaller rods so he fitted a curve to his experimental data and extrapolated to much smaller diameters. And lo and behold, the exponential curve converged to a failure strength of 11,000 MPa – much closer to the 14,000 MPa predicted by his theory.
Variation of tensile strength with fibre diameter. From W.H. Otto (1955). Relationship of Tensile Strength of Glass Fibers to Diameter. Journal of the American Ceramic Society 38(3): 122-124.
Griffith’s next goal was to explain why the strength of thicker glass rods fell so far below the theoretical value. Griffith surmised that as the volume of a specimen increases, some form of weakening mechanisms must be active because the underlying chemical structure of the material remains the same. This weakening mechanism must somehow lead to an increase in the actual stress around a future failure site and act as a stress concentration. Luckily, the idea of stress concentrations had previously been introduced in the naval industry, where the weakening effects of hatchways and other openings in the hull had to be accounted for. Griffith decided that he would apply the same concept at a much smaller scale and consider the effects of molecular “openings” in a series of chemical bonds.
The idea of a stress concentration is quite simple. Any hole or sharp notch in a material causes an increase in the local stress around the feature. Rather counter-intuitively, the increase in local stress is solely a function of the shape of the notch and not of its size. A tiny hole will weaken the material just as much as a large one will. This means a shallow cut in a branch will lower the load-carrying capacity just as well as a deep one – it is the sharpness of the cut that increases the stress.
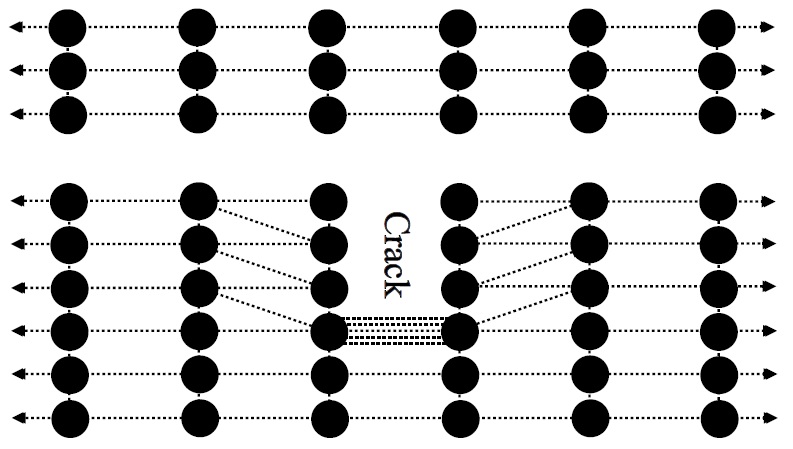
We can visualise quite easily what must happen at a molecular scale when we introduce a notch in a series of molecules. A single strand of molecules must reach the maximum theoretical strength. Similarly, placing a number of such strands side by side should not effect the strength. However, if we cut a number of adjacent strands at a specific location perpendicular to the loading direction, then the flow of stress from molecule to molecule has been interrupted and the load in the material has to be redistributed to somewhere else. Naturally, the extra load simply goes around the notch and will therefore have to pass through the first intact bond. As a result, this bond will fail much earlier than any of the other bonds as the stress is concentrated in this single bond. As this overloaded bond breaks, the situation becomes slightly worse because the next bond down the line has to carry the extra load of all the broken bonds.
Stress concentration at a notch
The stress concentration factor of a notch of half-length and radius of curvature at the crack tip is given by
If we now consider a crack about 2 long and 1 Angstrom tip radius, this produces a stress concentration factor of
and therefore this would lower the theoretical strength of glass from 14,000 MPa to around 70 MPa, which is very close to the average strength of typical domestic glass.
As a result, Griffith made the conjecture that glass and all other materials are full of tiny little cracks that are too small to be seen but nevertheless significantly reduce the theoretical maximum strength. Griffith did not give an explanation for why these cracks appeared in the first place or why they were rarer for thinner glass rods. As it turns out, Griffith was correct about the mechanism of stress concentration, but wrong about their origins.
It took quite some time until a more satisfactory explanation was provided, dispelling the notion that the reduction in strength could be attributed to inherent defects within the material. After WWII, experiments showed that even thick glass rods could approach the theoretical upper limit of strength when carefully manufactured. It was also noticed that stronger fibres would weaken over time, probably as a result of handling, and that weakened fibres could consequently be strengthened again by chemically removing the top surface. By depositing sodium vapour on the external surface of glass, the density of cracks could be visualised and was found to be inversely proportional to the strength of the glass – the more cracks, the lower the strength, and vice versa.
These cracks are a simple result of scratching when the exterior surface comes in contact with other objects. Larger pieces of glass are more likely to develop surface cracks due to the larger surface area. Furthermore, thin glass fibres are much more likely to bend when in contact with other objects, and are therefore less likely to scratch. This means that there is nothing special about thin fibres of glass – if the surface of a thick fibre can be kept just as smooth as that of a thin fibre then it will be just as strong.
This means that an airplane cast from one piece of 100% pristine glass could theoretically sustain all flight loads, such an idea ludicrous in reality, because the likelihood of inducing surface cracks during service is basically 100%.
At this point you might be asking, what is different about metals – why are they used on aircraft instead?
The difference boils down to differences between the atomic structure of glasses and metals. When liquids freeze they typically crystallise into a densely packed array and form a solid that is denser than the liquid. Glasses on the other hand do not arrange themselves into a nicely packed crystalline structure but rather cool into a purely solidified liquid. Glasses can crystallise under some circumstances under a process known as devitrification, but the glass is often weakened as a result. When a solid crystallises, it can deform via a new process in which it starts to flow in shear just like Plasticine or moulding clay does when it is formed.
There is no clear demarcation line between a brittle (think glass) and ductile (think metal) material. The general rule of thumb is that a brittle material does not visibly deform before failure and failure is caused by a single crack that runs smoothly through the entire material. This is why it’s often possible to glue a broken vase back together.
In ductile materials, there is permanent plastic deformation before ultimate failure and so these materials behave more like moulding clay. Before a ductile material, like mild steel, finally snaps in two, there is considerable plastic deformation which can be imagined along the lines of flowing honey or treacle. This plastic flowing is caused by individual layers of atoms sliding over each other, rather than coming apart directly. As this shearing of atomic bonds takes place, the material is not significantly weakened because the atomic bonds have the ability to re-order, and the material may even be strengthened by a process known as cold working (atomic bonds align with the direction of the applied load). The amount of shearing before final failure depends largely on the type of metal alloy and always increases as a metal is heated; hence a blacksmith heats metal before shaping it.
Generally, these two fracture mechanism, brittle cracking and plastic flowing, are always competing in a solid. The material will break in whatever mechanism is weakest; yield before cracking if it is ductile or crack directly if it is brittle.





 by Prof. J E Gordon